Hello! I am a fourth-year Ph.D. student in Robotics at Georgia Tech, advised by Shreyas Kousik.
My research focuses on reliable robot learning, particularly for dynamic and dexterous behavior. My goal is to let robots expand their capabilities beyond what they were trained on while avoiding irrecoverable failures. To this end, I work on composing and extrapolating learned skills under model-based reliability critics. I validate these frameworks on physical robots, not in simulation alone.
I have interned with the Large Behavior Models (LBM) team at Toyota Research Institute and the Hybrid Robotics Lab at UC Berkeley. I am fortunate to work with many wonderful collaborators.
I received my B.S. in Mechanical Engineering and Artificial Intelligence from Seoul National University, and my Ph.D. is supported by the Kwanjeong Educational Foundation. I also help organize the Korean-American Robotics Association and the Georgia Tech Robotics Graduate Student Organization.
News
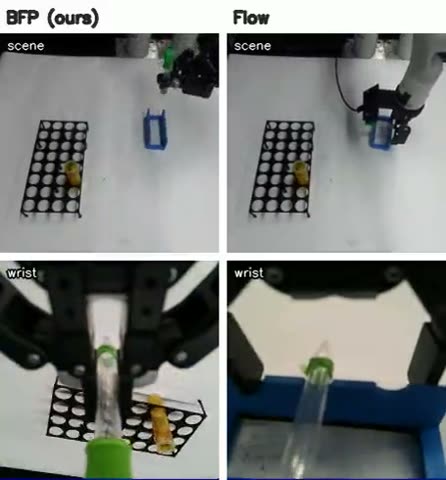
- Oct 2026 New preprint on goal-conditioned imitation that extrapolates to goals outside the demonstrations: BFP.
- Sep 2026 New preprint on a faster-than-demonstration framework built from cheap play data: EPCC.
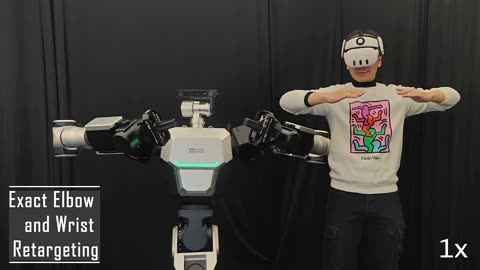
- Feb 2026 New paper on fast, precise upper-body teleoperation: SEW-MIMIC.
- Sep 2025 Our paper on safe active learning is accepted at the Open Journal of Control Systems (OJ-CSYS).
- Aug 2025 Two papers accepted at CoRL 2025: a diffusion planning framework with hard constraints, and a faster-than-demonstration IL policy. See you in South Korea!
- Jul 2025 Our work on a scalable data-driven safety filter using online data selection is accepted at T-RO.
- Jun 2025 New paper on faster-than-demonstration execution of imitation learning policies: SAIL.
- May 2025 I am spending the summer at Toyota Research Institute as a Research Intern on the Large Behavior Models (LBM) team.
- Jan 2025 Two papers, RAIL and NeuralPARC, are accepted at ICRA 2025. See you in Atlanta!
- Nov 2024 RAIL is accepted as a poster at the CoRL 2024 Workshop on Safe Robot Learning (SAFE-ROL).
- Oct 2024 New paper introducing a continuous-time safety envelope for imitation learning policies: RAIL, in collaboration with Dr. Danfei Xu.
- Jul 2024 I presented NeuralPARC at the RSS 2024 Workshop on Towards Safe Autonomy, in Delft.
- May 2024 Our paper PARC is accepted at RSS 2024. See you in Delft!
- Aug 2023 I started my Robotics Ph.D. at Georgia Tech, under the guidance of Dr. Shreyas Kousik.
- May 2023 I received the Kwanjeong Education Foundation (KEF) Scholarship.
Publications
-
Bilinear Flow Policy: Distributional Extrapolation for Goal-Conditioned Visuomotor Imitation
Work done during an internship at Toyota Research Institute
TL;DR: A goal-conditioned visuomotor policy that structurally extrapolates to goals outside the demonstrations, pairing transductive retrieval with a bilinear conditional flow for 2.63x the out-of-distribution success rate.
-
Expert-Play Contouring Control: Faster-than-Demonstration Planning from Slow Expert and Fast Play
* equal contribution
TL;DR: A faster-than-demonstration framework for dynamic tasks that uses a world model learned from cheap play data to exceed the speed of the expert demonstrations.
-
A Closed-Form Geometric Retargeting Solver for Upper Body Humanoid Robot Teleoperation
TL;DR: A fast, closed-form solver for human-to-humanoid bimanual retargeting that runs in constant time, handling singularities that trip up iterative optimization.
-
Joint Model-based Model-free Diffusion for Planning with Constraints
TL;DR: A diffusion framework for planning under hard constraints, combining a model-based and a model-free score in a single denoising process to enforce constraints without sacrificing performance.
-
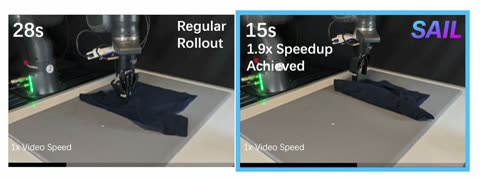
SAIL: Faster-than-Demonstration Execution of Imitation Learning Policies
Oral presentation
TL;DR: A faster-than-demonstration framework for imitation learning policies that executes them 3.2x faster than the demonstration data while keeping task success.
-
Constraint-Guided Online Data Selection for Scalable Data-Driven Safety Filters in Uncertain Robotic Systems
* equal contribution
TL;DR: A data-driven safety filter for uncertain robotic systems that certifies safety online, with a constraint-guided data selection rule that keeps the Gaussian Process tractable.
-
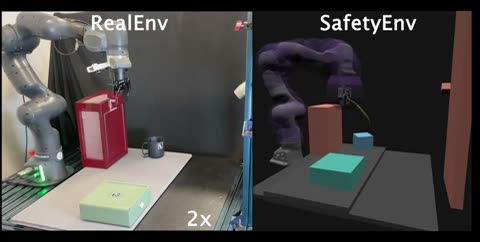
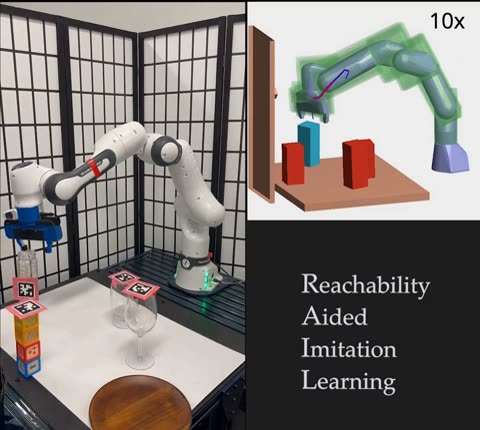
RAIL: Reachability-Aided Imitation Learning for Safe Policy Execution
Also at the CoRL 2024 Workshop on Safe Robot Learning
ICRA 2025 WebsitePaperVideoCode
TL;DR: A reachability-based safety filter for imitation learning policies that guarantees collision avoidance and, in practice, raises task success rather than lowering it.
-
Guaranteed Reach-Avoid for Black-Box Systems through Narrow Gaps via Neural Network Reachability
Also at the RSS 2024 Workshop on Towards Safe Autonomy
ICRA 2025 WebsitePaperVideoCode
TL;DR: A reach-avoid verification method for black-box systems that bounds the reachable sets of a neural network, certifying extreme maneuvers such as drift parking.
-
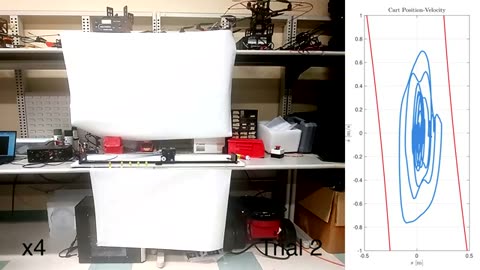
Recursively Feasible Probabilistic Safe Online Learning with Control Barrier Functions
TL;DR: A safe online learning framework for uncertain systems that stays recursively feasible, combining Control Barrier Functions with Gaussian Process regression and event-triggered data collection.
-
Goal-Reaching Trajectory Design Near Danger with Piecewise Affine Reach-Avoid Computation
* equal contribution
RSS 2024 WebsitePaperVideoCode
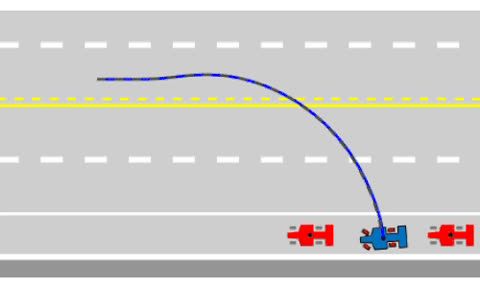
TL;DR: A reach-avoid planning method for extreme, hybrid dynamics that keeps reachable-set approximations tight enough to stay non-conservative, planning maneuvers such as drifting through narrow gaps.
-
Dynamics-Aware Metric Embedding: Metric Learning in a Latent Space for Visual Planning
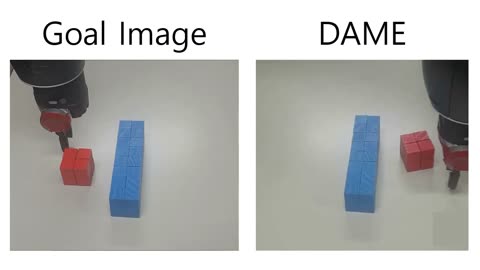
TL;DR: A latent metric learned from probabilistic reachability that lets visual planning toward an image-defined goal produce dynamically feasible paths.
Experience
-
 Research Intern, Large Behavior Model (LBM) Team May 2025 – Aug 2025Trustworthy Learning under Uncertainty, Toyota Research Institute · Los Altos, CA
Mentors Haruki Nishimura, Masha Itkina
Failure recovery and out-of-distribution generalization for manipulation policies.
- Kait AI Research Scientist, Machine Learning Team Lead Jun 2022 – Dec 2022Knowledge AI (Kait) · Boston, MA
Data-driven interactive learning platform for mathematics. Built ML models that estimate student knowledge and recommend personalized problems, deployed in public elementary schools across Jordan and the UAE.
-
 Robotics Research Intern Aug 2021 – Jul 2023Hybrid Robotics Lab, UC Berkeley · Berkeley, CA
Mentors Koushil Sreenath, Jason J. Choi
Safe online learning & control for uncertain robotic systems (e.g., legged robot).
-
 Robotics Research Intern Aug 2021 – Jun 2022Robust Perception and Mobile Robotics Lab, SNU · Seoul, South Korea
Mentor Ayoung Kim
Robust localization for legged robots using foot contact information, and a visual localization pipeline with learned point-line features (4th place, ICCV 2021 Visual Localization Challenge).
- Robotics Research Intern Mar 2021 – Aug 2021Robot Learning Lab, SNU · Seoul, South Korea
Mentor Songhwai Oh
Visuomotor policies for manipulators: manifold learning for motion planning, and MPC on a learned manifold.
- Rbs AI Research Intern Dec 2020 – Feb 2021Roborus Inc., Machine Learning Team · Seoul, South Korea
Patient fall-detection for hospital settings: face recognition and detection, object detection, and human pose estimation.
- Autonomy Engineer, Robot Perception Team Mar 2020 – Oct 2020SNU ZERO · Seoul, South Korea
Mentor Kyongsu Yi
Autonomous driving: object detection and tracking, lane and traffic-light detection, road estimation, and localization via sensor fusion.
-
 Software Engineering Intern, Computer Vision Team Jan 2020 – Mar 2020Samsung · Seoul, South Korea
Education
-
 Ph.D. in Robotics Aug 2023 – PresentGeorgia Institute of Technology · Atlanta, GA
Institute for Robotics and Intelligent Machines (IRIM)
- B.S. in Mechanical Engineering & Artificial Intelligence Mar 2016 – Aug 2022Seoul National University · Seoul, South Korea
Summa Cum Laude. Leave of absence May 2018 – Jan 2020 for military service.
Collaborators
Shreyas Kousik (advisor)·Danfei Xu·Yongxin Chen
Jason J. Choi·Fernando Castañeda·Bike Zhang·Claire J. Tomlin·Koushil Sreenath
Service & Community
T-RO, IJRR, RA-L, NeurIPS, ICLR, CoRL, ICRA, IROS
Honors & Awards
- Overseas Scholarship for Graduate Study May 2023Kwanjeong Educational Foundation
One of the top Korean scholarships for overseas graduate study.
- Dean's Special Appreciation Award (2x) Aug 2022, Jul 2021College of Engineering, Seoul National University
For establishing a scholarship for young engineers, and for work at the forefront of AI education in Korea.
- SNU Engineering Honor Society (STEM) 2020 – 2021College of Engineering, Seoul National University
11th president, currently an honorary member.